
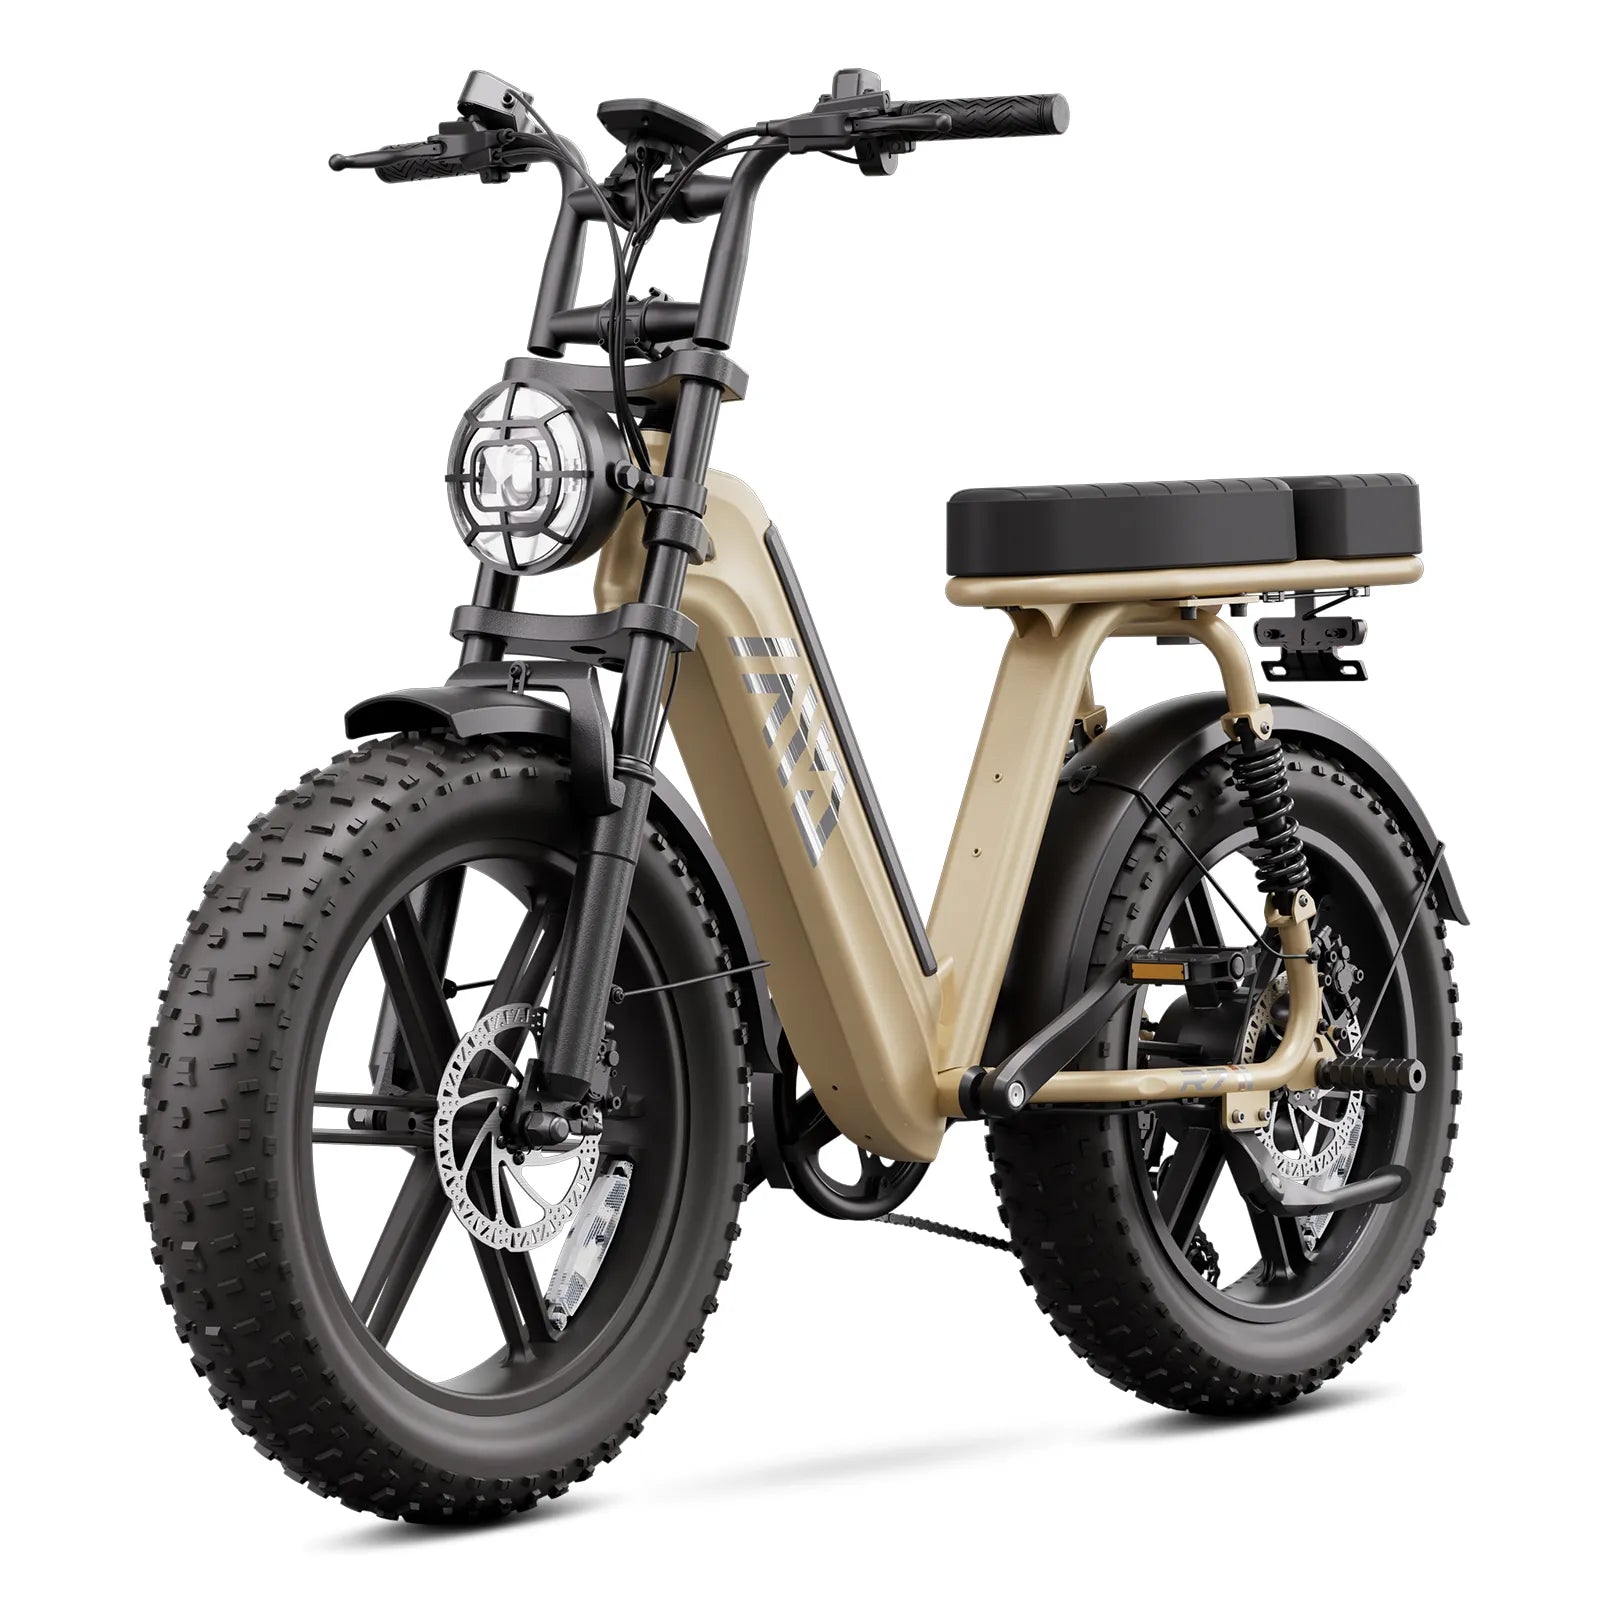
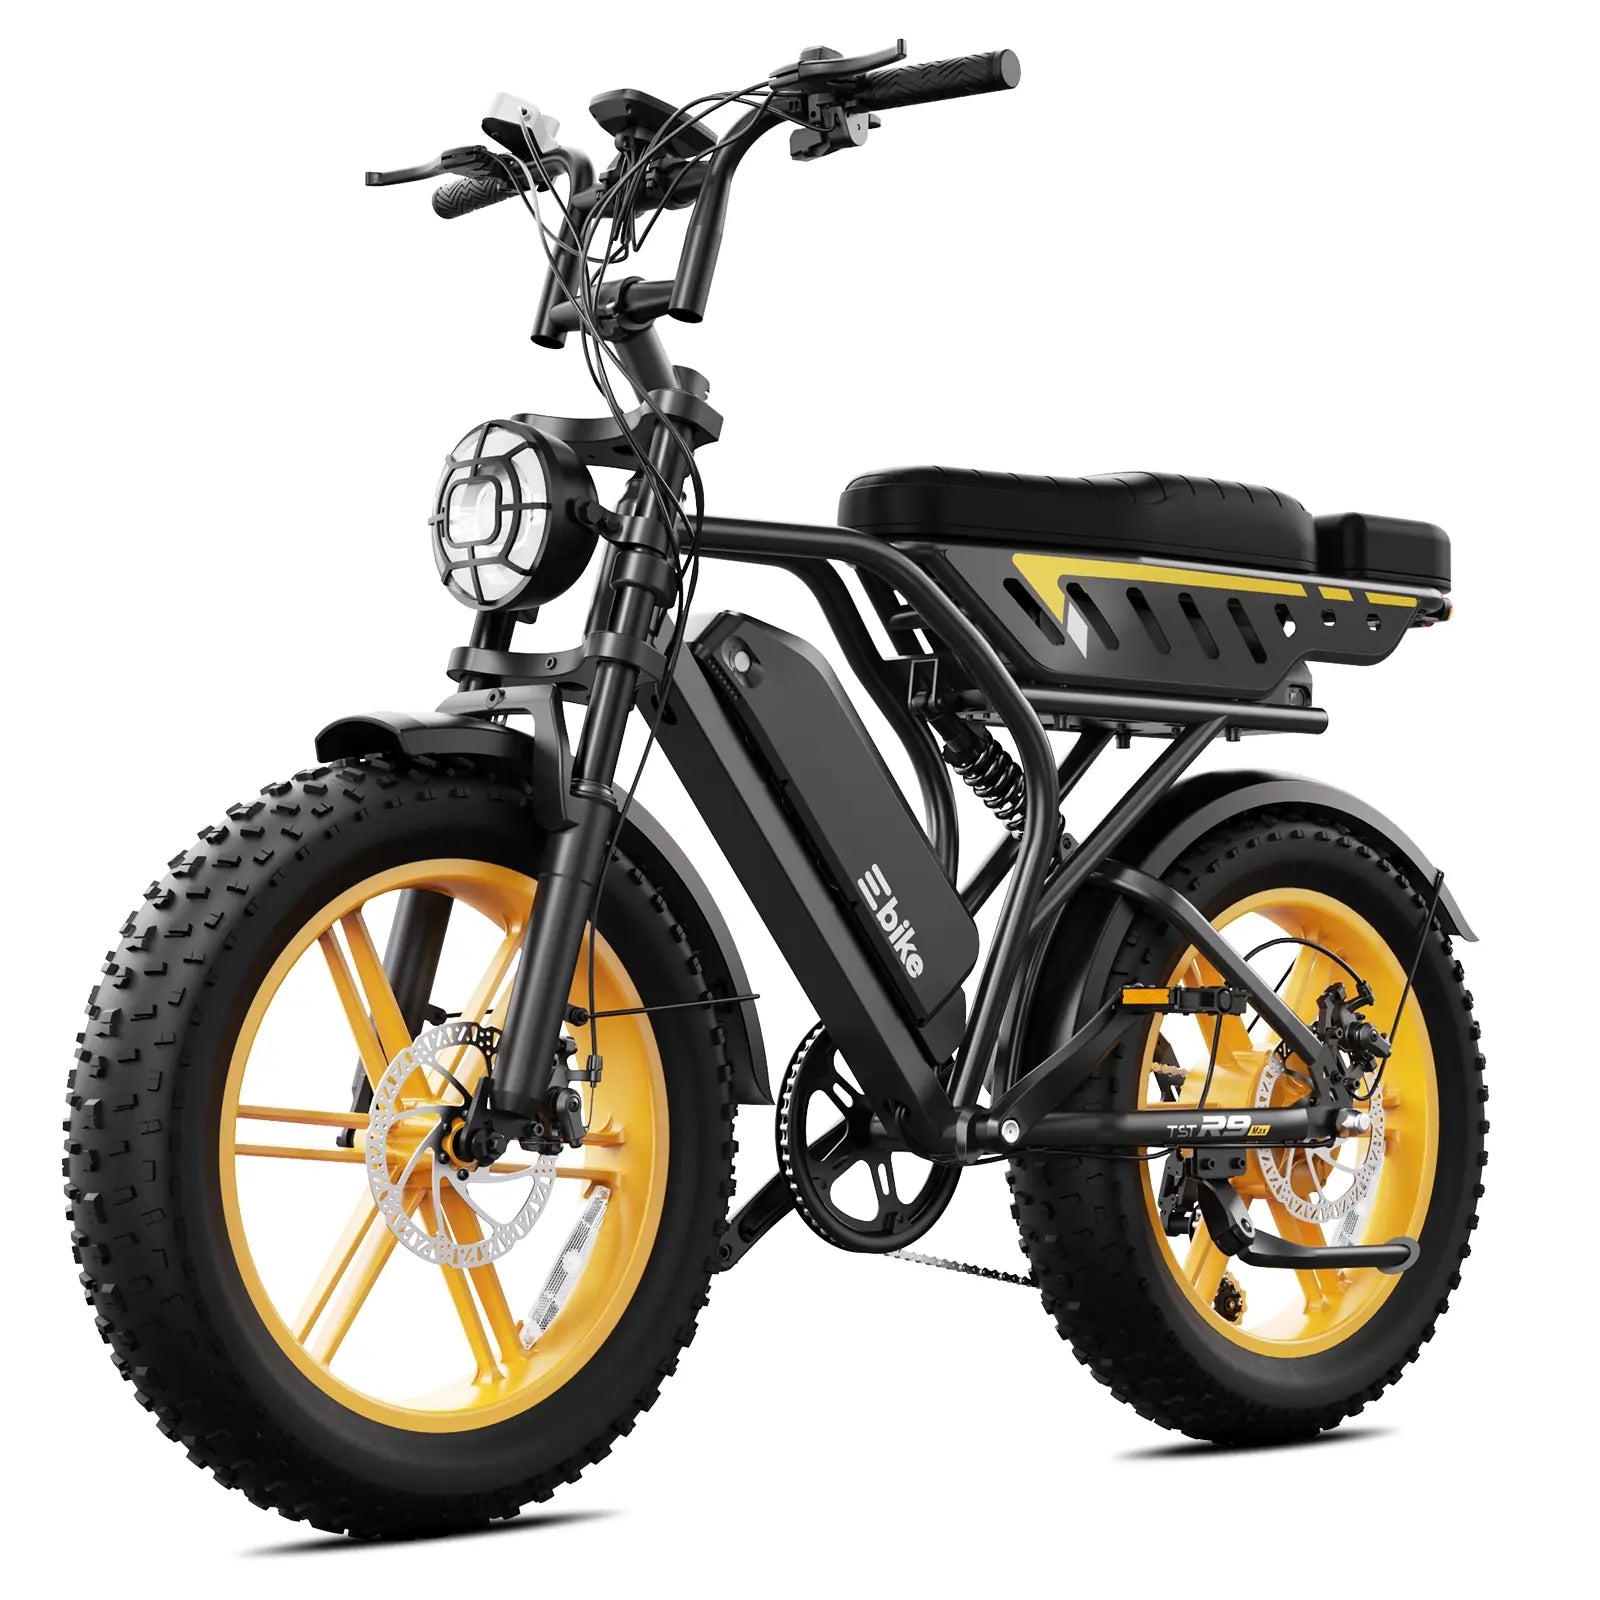
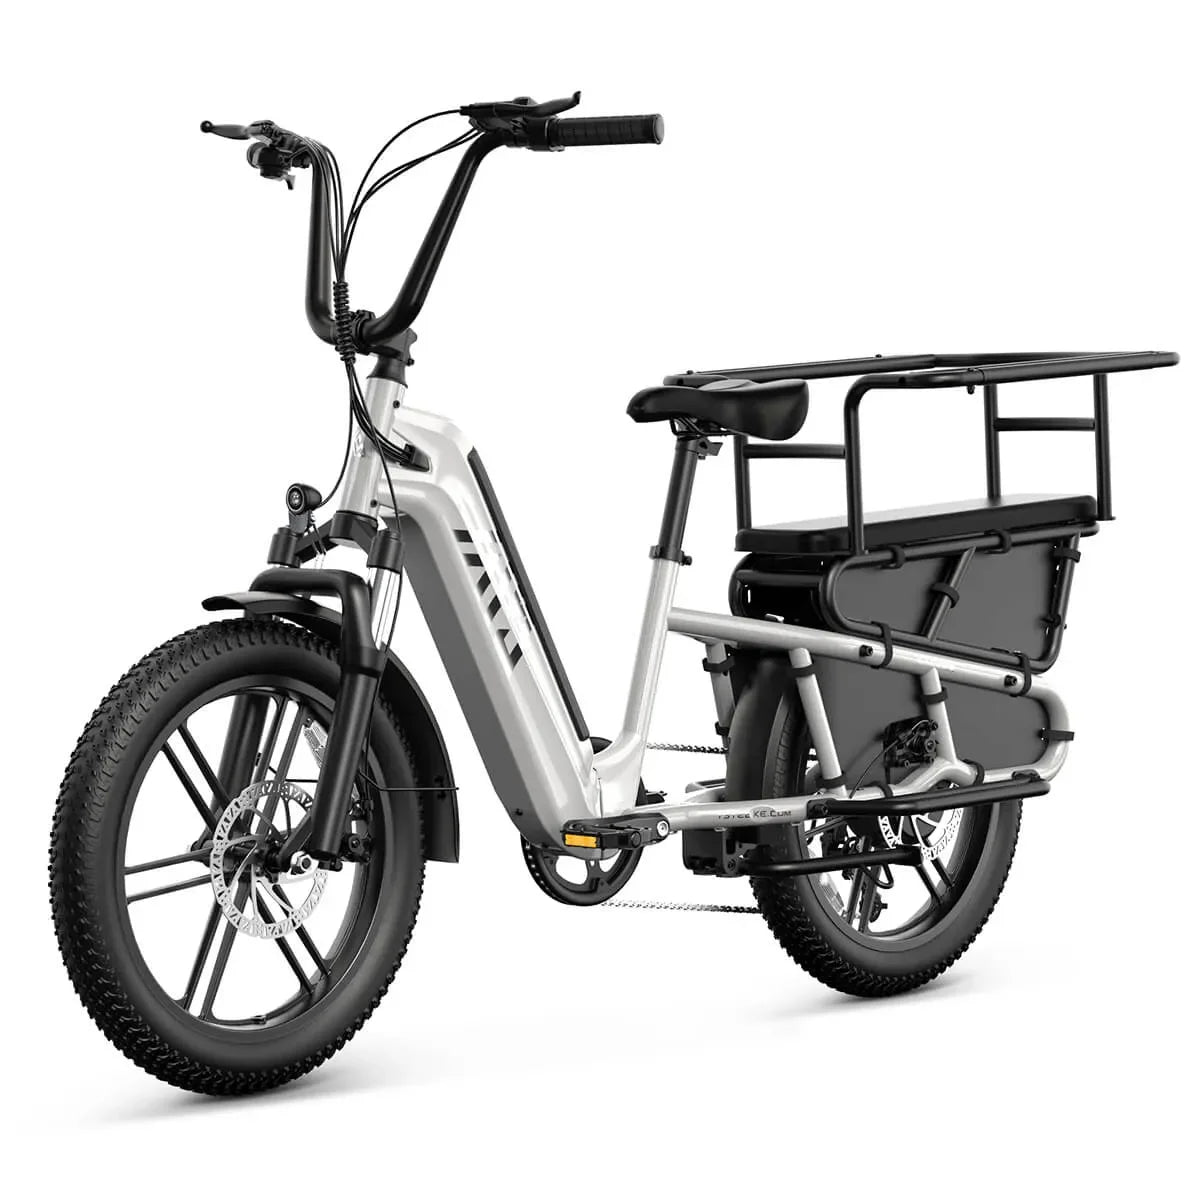
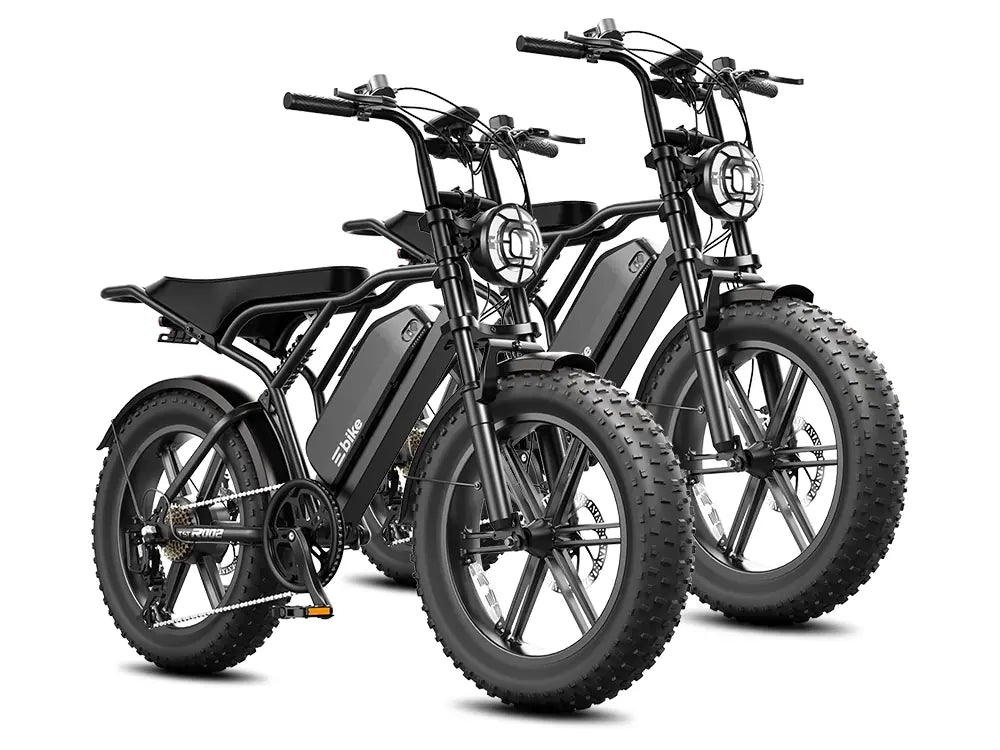
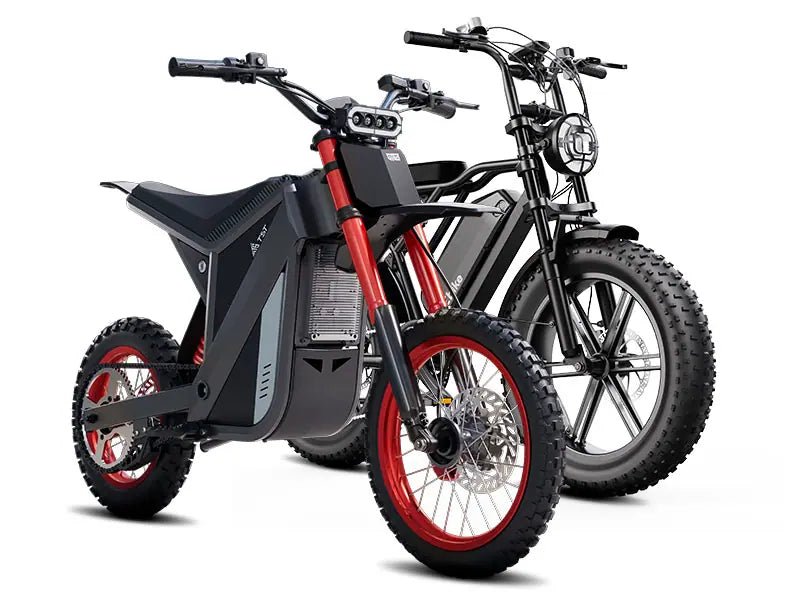
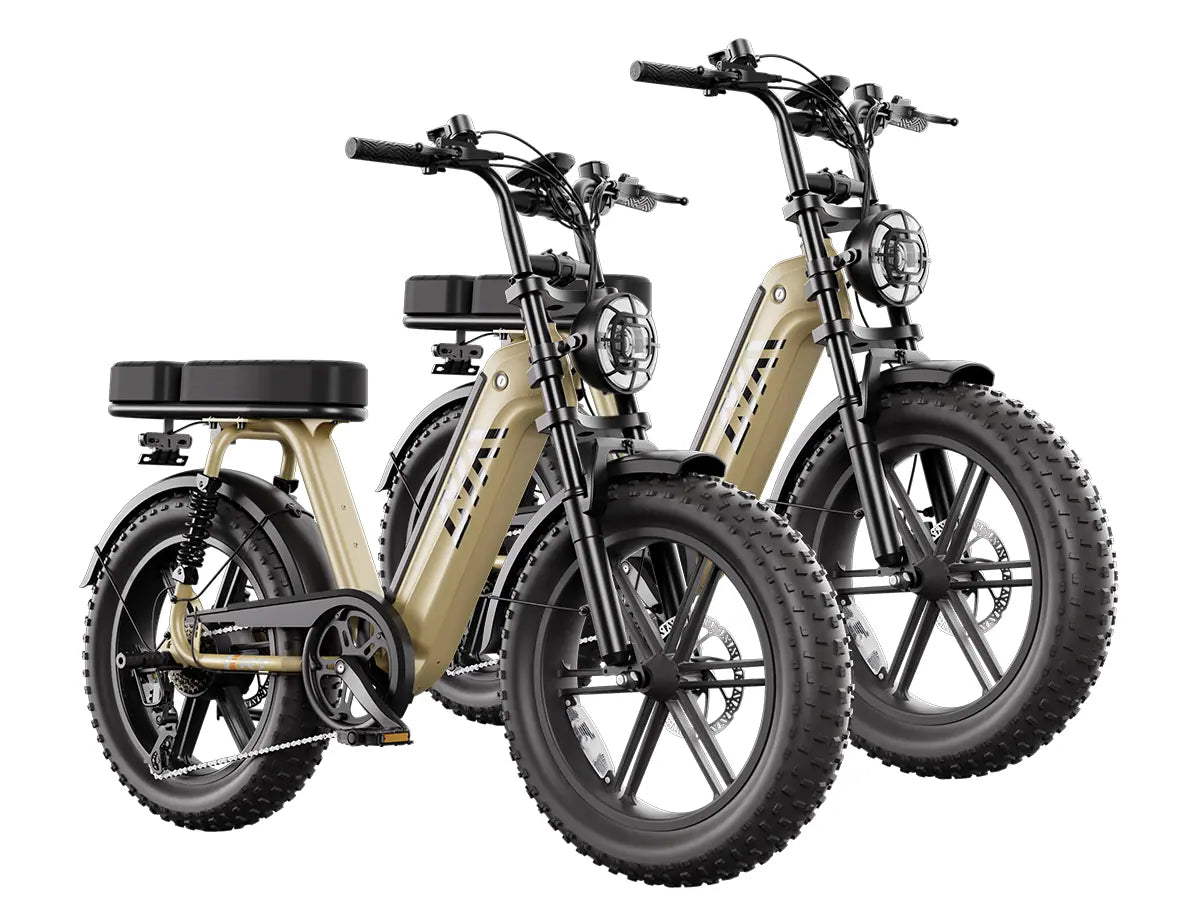
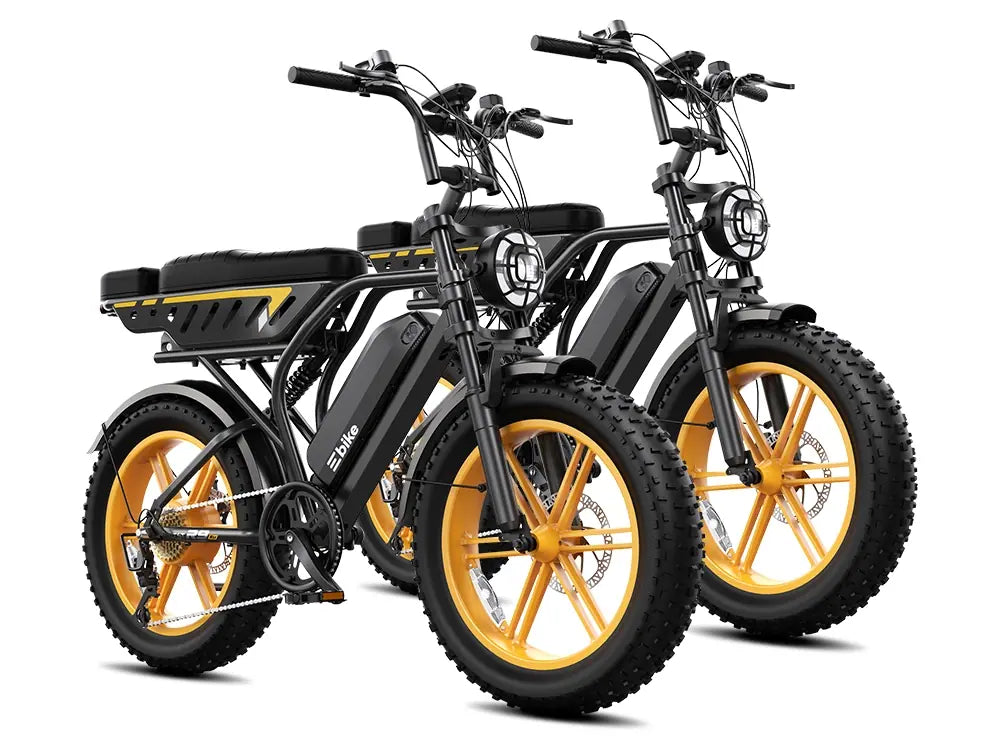
A heavier rider does not automatically need a mid-drive motor, and a hub motor is not automatically the wrong choice. What actually separates the two systems for a rider carrying more mass is how each one behaves under sustained load: how torque reaches the ground, how much heat builds up on a long climb, how the drivetrain absorbs that stress over time, and how easy the resulting wear is to service. Weight is one input into that equation, not the whole equation.
This matters because most buying guides frame the choice as a simple watts-and-torque scoreboard, then declare mid-drive the universal winner for hills and cargo. That shortcut skips the part that actually affects a heavier rider day to day: whether their specific climbs are short traffic-light ramps or long sustained grades, how often they start from a dead stop, what surface they ride on, and who is going to service the drivetrain when it wears out faster under load. Those four variables — grade length, start frequency, surface, and service access — do more to determine the right system than rider weight alone.
How Torque Reaches the Wheel, and Why That Changes Under Load
A hub motor drives the wheel directly, with the stator and rotor built into the wheel hub itself, so power delivery bypasses the bicycle's chain and gears entirely. A mid-drive motor instead mounts at the bottom bracket and sends power through the bike's chain, cassette, and derailleur, which means it can multiply torque using the bike's own gear ratios. That mechanical difference is the whole reason the two systems behave differently as load increases.
Because a mid-drive can shift into a lower gear before or during a climb, it can keep its motor spinning in a more efficient RPM range even when the combined rider-and-cargo weight is high. A direct-drive (gearless) hub motor has no such option: it is turning the wheel at whatever RPM the wheel's speed dictates, regardless of load, which is efficient at cruising speed but comparatively inefficient at the low wheel speeds a heavy rider produces on a steep grade. Geared hub motors close part of that gap with an internal planetary gearset that trades some top-end efficiency for better low-speed torque, which is why TST's own comparison of hub types treats geared and gearless hubs as functionally different products rather than a single category.
None of this changes what the complete bike is rated to carry. A drive type does not certify a payload; the manufacturer's stated rider-plus-cargo limit for that exact model does, and that figure should come from the specific product listing rather than being inferred from motor type.
The Real Variable Is Grade Length and Start Frequency, Not Just Grade
Two riders can face the same 8% grade and need different systems, because the deciding factor is how long that grade lasts and how often the rider has to restart on it. A short, steep ramp that a rider hits once and clears in fifteen seconds is a very different thermal and mechanical event than a mile-long sustained climb, even if the percentage grade is identical.
On a short grade, a hub motor's comparative inefficiency at low RPM matters less, because the motor never stays in that inefficient zone long enough to build significant heat. The battery absorbs a brief high-current draw and the ride continues. On a long sustained grade, the same low-RPM, high-current condition persists for minutes rather than seconds, and that is where heat becomes the limiting factor rather than raw torque.
Start frequency compounds this in stop-and-go conditions. Every full stop followed by a restart is a moment of maximum current draw at zero or near-zero motor RPM, which is the single hardest condition on any electric motor's windings and controller. A heavier total system mass increases the torque needed to get moving again, which increases that current draw further. A commuter route with frequent stop signs and a loaded cargo rack sees far more of these high-stress restart events per mile than a rider doing one long uninterrupted climb, even if the second rider is carrying more total weight overall. Surface matters here too: loose gravel, wet pavement, or soft trail surfaces increase the torque needed for the same restart because wheel slip forces the motor to work harder to regain traction, while a firm, dry road surface lets the same torque translate into forward motion more efficiently.
Gearing Changes the Comparison More Than the Motor Label Does
The motor type gets the marketing attention, but the mechanical gearing behind it does more to determine hill performance under load. A mid-drive's advantage on paper comes entirely from being able to use the bike's gear range; a mid-drive stuck in too high a gear on a steep climb loses most of that advantage and can strain its own chain and cassette in the process, since the motor's torque is being multiplied through parts not designed for sustained high load in the wrong gear.
A geared hub motor's internal gearing is fixed by the manufacturer and cannot be adjusted by the rider, so its climbing behavior is more predictable but has a hard ceiling: whatever internal gear ratio the motor was built with is the ratio it will always use, regardless of terrain. Wheel size interacts with this as well. A larger wheel diameter increases the leverage the motor has to overcome per unit of torque, which is one reason many higher-torque cargo and moped-style hub setups pair a strong motor with a fat, lower-diameter tire rather than a larger wheel — the smaller diameter partly compensates for the added leverage penalty a bigger wheel would introduce.
Heat Is the Failure Mode That Actually Limits Sustained Climbing
Every motor has a continuous power rating and a separate peak power rating, and the two describe different things: continuous power is what the motor can sustain without overheating, while peak power is a short-duration figure the motor can produce briefly before heat buildup forces the controller to cut back or shut down. Marketing materials frequently list only the peak figure, which is one reason a spec sheet showing an impressively high wattage can be misleading about how the bike will actually perform on a ten-minute climb rather than a ten-second sprint.
A direct-drive hub motor sits inside the wheel with limited airflow, and TST's own hub-motor reference material identifies heat management under sustained heavy use as a specific disadvantage of the enclosed design. A mid-drive motor is mounted at the bottom bracket, generally more exposed to airflow, but it transmits its heat-generating effort through the external drivetrain, so mechanical stress shows up as chain and cassette wear rather than motor casing temperature. Reporting on gear-shifting technique for e-bike motors describes the same failure pattern from a different angle: riding in too high a gear at low speed — "lugging" the motor — forces it to draw excessive current at low RPM, which raises internal winding temperature regardless of drive type, though the practical consequence differs by system: a hub motor lugged this way risks motor and controller heat damage, while a mid-drive lugged the same way adds extreme instantaneous load to the chain and derailleur on top of the heat risk.
For a heavier rider, this means the practical question isn't "which motor tolerates heat better" in the abstract — it's "how long is my typical climb, and does my riding habit keep the motor in an efficient RPM range." A rider who shifts down before a hill and keeps a brisk cadence reduces heat buildup on either system. A rider who stays in a high gear and relies on raw torque to grind up a hill stresses whichever system they have.
Service Trade-Offs: Wheel Simplicity Versus Drivetrain Dependence
This is where the two systems diverge in ongoing cost and downtime, independent of which one climbs better on a given day.
A hub motor is electrically and mechanically isolated from the chain and gears, so the derailleur, cassette, and chain wear at roughly the same rate they would on a bike with no motor at all — routine cleaning, occasional lubrication, and periodic chain replacement rather than accelerated replacement. The trade-off shows up if the motor itself fails: because it's built into the wheel, a hub motor problem often means removing or replacing the entire wheel assembly, and TST's own maintenance comparison describes hub motor repair as requiring full wheel replacement in many failure cases rather than a simple part swap.
A mid-drive motor routes its power through the chain, cassette, and chainring, and every added watt of torque increases the mechanical stress on those parts under load. Industry maintenance guidance places mid-drive chain replacement at roughly 1,500 to 3,000 miles and cassette replacement around 3,000 to 5,000 miles under normal use, both shorter intervals than a comparable hub-driven bike typically sees, because the motor's torque runs through those same components on every pedal stroke rather than bypassing them. A heavier rider accelerates this further: more mass means more torque is needed for the same acceleration or climb, and that torque is multiplied through the mid-drive's drivetrain on every application, which is the direct mechanical link between added weight and faster chain and cassette wear on a mid-drive system specifically.
The service-access question that follows from this is straightforward: a hub motor's routine maintenance (cleaning, axle checks, wiring inspection) is something most owners can do themselves, but a motor-internal failure usually needs a wheel replacement or a service center. A mid-drive's routine maintenance (chain lubrication, cassette and chainring wear checks) is more frequent but often within reach of a rider comfortable with standard bicycle drivetrain tools, while integrated motor-internal repairs typically require specialized tools and factory-level service. Neither path is inherently cheaper over the ownership life; the mid-drive's failure points are more frequent and lower-cost per event, while the hub motor's are less frequent and potentially more disruptive per event.
A Practical Way to Match the Decision to a Route
This table describes tendencies documented in TST's own hub-motor and maintenance comparison material, not a guarantee for any specific bike. A rider's actual outcome still depends on the exact model's continuous power rating, its verified total payload limit, its gearing, and how the rider actually uses it — none of which can be assumed from the drive-type label alone.
What "Heavy Rider" Should Actually Check Before Deciding
Rider weight alone doesn't select a winner because the manufacturer's stated maximum load — covering rider, cargo, and accessories together — is a complete-bike figure set by the frame, wheels, brakes, and motor as a system, not by the motor type in isolation. A hub-motor bike rated for a high total payload and a mid-drive bike rated for a lower one can both exist; the drive type doesn't set that ceiling, the manufacturer's testing and specification for that exact model does. Before choosing based on motor type, a heavier rider should verify, for the exact model under consideration: the manufacturer's stated maximum combined rider-and-cargo load, the continuous (not peak) power rating, the exact battery voltage and amp-hour figures behind any range claim, and the recommended rider height and fit range, all of which should come from that model's own current product page or owner's manual rather than a general drive-type comparison.
For riders in Washington, there's a separate and unrelated ceiling to check before assuming any of this applies to public-road riding: state law defines a Class 1, 2, or 3 electric-assisted bicycle as capped at a 750-watt motor and either a 20 mph or 28 mph pedal-assist cutoff, and a 2026 amendment further excludes any device capable of exceeding 20 mph on electric motor power alone from the e-bike definition entirely. Several moped-style models sold with rear hub motors, including higher-output configurations in the 1,500-watt-and-up peak range with top speeds above 28 mph, fall outside those state thresholds regardless of drive type, which means the relevant question for road use in Washington is the bike's certified class and configuration, not whether it uses a hub or mid-drive motor. Drive type and legal classification are separate questions, and neither one answers the other.
Buyers comparing specific current models — rated versus peak power, torque figures, battery configuration, and which drive type each model actually ships with — should check the exact current specifications on the TST model comparison page, since those figures change by model and are maintained there rather than in general drive-type explainers.

Leave a comment
This site is protected by hCaptcha and the hCaptcha Privacy Policy and Terms of Service apply.